Trace a paraxial ray through spaces and lenses, then use the agreement of many rays to test whether a system forms an image.
The engineering question
A thin-lens equation predicts an image plane for one ideal lens. For several lenses, drawing principal rays becomes cumbersome. How do we trace rays through successive spaces and lenses without redrawing the system from scratch each time?
A small-angle approximation lets us describe each propagation and refraction step with a matrix. We write the state of one ray as a two-component vector, then apply the matrices in the order the ray encounters the system.
Model
Paraxial rays in a centered system
A paraxial ray stays near the optical axis and makes a small angle with it. With the angle measured in radians, the small-angle approximation is . This lets us use the angle itself in place of the ray’s geometric slope.
At axial coordinate , represent a ray by its transverse height and its small angle from the positive direction.
Valid when: the system is centered, one meridional – plane is sufficient, and angles are small enough that .
Omitted effects: diffraction, aberrations, finite apertures, and strongly nonparaxial rays. These topics will be introduced later in the course.
A ray has a height and a slope
Figure 1.3. A single optical element maps the ray state at its input plane to the ray state at its output plane.
Positive is upward from the optical axis. Positive means the ray height increases as it propagates in positive ; a downward-sloping ray has negative .
Two building blocks
For propagation through a positive physical distance in a uniform medium, the angle stays fixed. Geometry gives the exact height change:
For small angles, this becomes
The resulting linear transformation is
At a thin lens, the ray height is unchanged. The corresponding first-order angle rule is
For a lens at , this gives the matrix below. A converging lens has :
A ray above the axis is bent downward by a positive lens, as it should be. We use equality when applying these matrices within the paraxial model; their agreement with physical ray propagation remains an approximation.
How small must the angle be? Replacing with underestimates the exact free-space transverse displacement by approximately 0.25% at 5°, 1.0% at 10°, 5.2% at 22.5°, and 21% at 45°. The acceptable angle therefore depends on the accuracy required. These percentages describe the propagation approximation, not the total error of an optical system.
A meridional slice of a three-dimensional lens
The three-dimensional lens is rotationally symmetric about the optical axis. Our – diagram represents a meridional plane: a slice containing that axis. Rotating this slice about the axis gives other meridional planes. Within the slice, and are Cartesian coordinates; the lens is not formed by extending the drawing perpendicular to the page.
The ray-transfer coordinates are signed. The height is positive above the axis and negative below it, whereas cylindrical radial distance is . The ray angle is measured from toward the ray’s direction: positive for a ray sloping toward increasing , and negative for one sloping toward decreasing . It is analogous to the spherical polar angle of the ray’s direction, but the usual spherical polar angle is nonnegative; here, the sign distinguishes the two directions of tilt within the chosen plane.
Follow the ray, read products from right to left
Suppose a ray propagates a distance to a lens, passes through the lens, and then propagates a distance to a sensor. The physical sequence is written
The first physical operation, , is the rightmost matrix because it acts on the input vector first. Here and are positive path lengths. They are not the signed object and image coordinates: for a real object at and a real sensor at .
The system matrix gives an imaging test
Multiply every step to describe the whole system as one matrix:
The image-plane height is therefore . A focused image plane requires : then every paraxial ray from the same object height has the same final height, regardless of its initial slope. This is the matrix version of imaging.
For the single-lens sequence above, multiply using the signed coordinates of Chapter 1.1. Its imaging condition is
Thus the matrix model recovers the ideal thin-lens imaging relation. The angle-based matrices themselves still require the small-angle approximation. Because its four entries are conventionally labeled , a ray transfer matrix is also called an ABCD matrix, and the method is known as ABCD matrix analysis.
An image brings many rays to one point
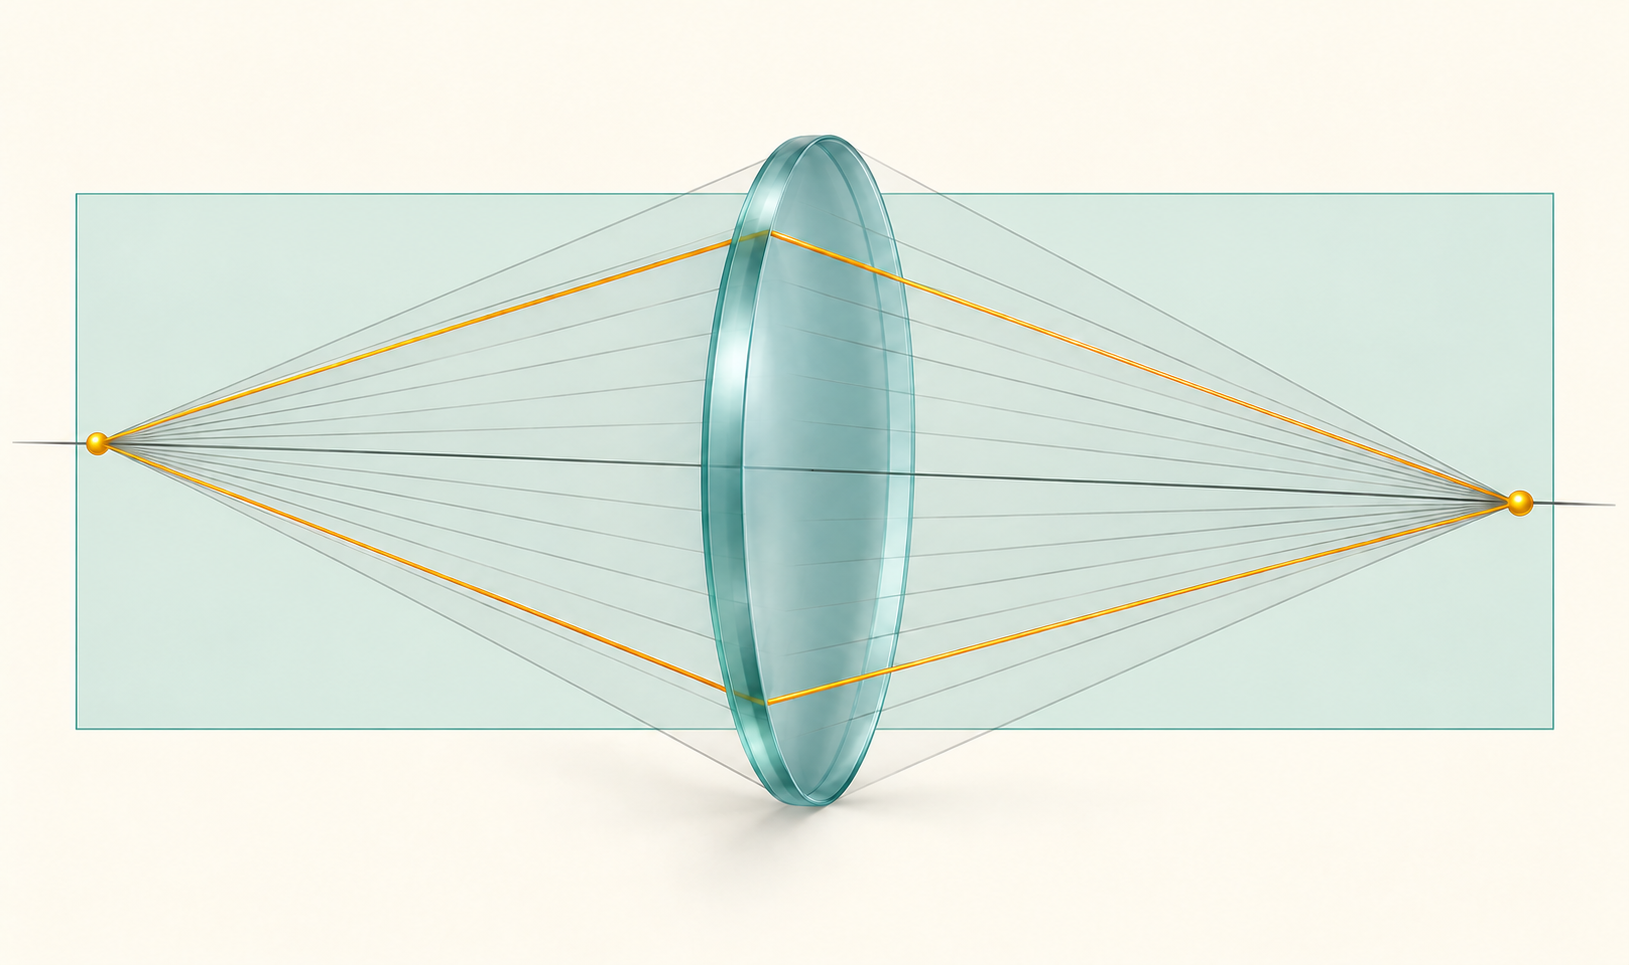
A correctly focused ideal system sends every paraxial ray leaving one object point to the same image-plane height. The rays may have different angles at the object, lens, and sensor, but their final agrees.
Figure 1.4. For a 100 mm focal-length lens, a point at maps to . Different initial slopes produce the same final height when the sensor is at the image plane.
Explore: move the sensor plane
Start from the Figure 1.4 system, then move the sensor while the rays leave the same object point with different initial slopes. The explorer makes the coefficient observable: the sensor fan collapses only when . The controls use positive physical path lengths, so and . We use x_s for the height where a ray reaches the sensor. When the sensor lies at the focused image plane, all rays from one object point share the same height, and x_s = x_i.
Worked examples
Guided
Propagate one ray
At one plane, a ray has and . Propagate it in free space. What are its new height and angle?
Hint / setup
Write the input ray as , then apply the free-space matrix . Use millimetres for both height and propagation distance. Before multiplying, predict whether the ray height increases or decreases; its angle stays unchanged.
Full solution
Using millimetres for the height and distance gives and . The negative slope lowered the ray by .
Scaffolded
Focus a finite calibration target
A surgical-imaging camera is checked with a calibration target. Its lens has . A feature on the target is located an axial distance to the left of the lens and a height above the optical axis. Find the exact sensor distance and image height in the paraxial thin-lens model. Then show that the sensor height is independent of the ray’s initial slope .
Hint / setup
Use millimetres: and . The target subtends a small angle, approximately . Restrict the traced bundle to rays whose angles remain small before and after the lens. Start with , apply , , and , and set the coefficient of to zero.
Full solution
The sensor-height coefficient of is
Imaging requires , so
At that distance, the sensor height is independent of and equals
This agrees with the signed thin-lens relation : , , and . The image is inverted. This focus location is exact within the paraxial thin-lens model. Here the sensor must move beyond , an shift relative to the focal length, so is not a good approximation.
Independent
Trace rays from a sample point
A point in a sample is at . A lens with is at , and a sensor is at . Show that rays with different initial slopes all reach the same sensor coordinate. Check against the magnification from Chapter 1.1.
Hint / setup
Write the input vector as . The propagation distances are and .
Full solution
Expanding the height calculation gives and . Therefore
The result does not depend on . From Chapter 1.1, , so , in agreement.
Before you trust the answer
Model selection and engineering checks
Are the ray angles small at every stage, including immediately after each lens, so that is a useful approximation?
Do the lengths in each propagation matrix use the same unit as the ray height?
Does the rightmost matrix describe the first physical operation?
Does a centered system preserve an on-axis ray with ?
For an image plane, do rays from one object point reach a common output height? If not, is the sensor misplaced, or is the model missing an effect such as aperture clipping or aberration?